Industrial PLC-Robot-Conveyor Control System (M.S. Thesis)

Industrial PLC-Robot-Conveyor Control System (M.S. Thesis)

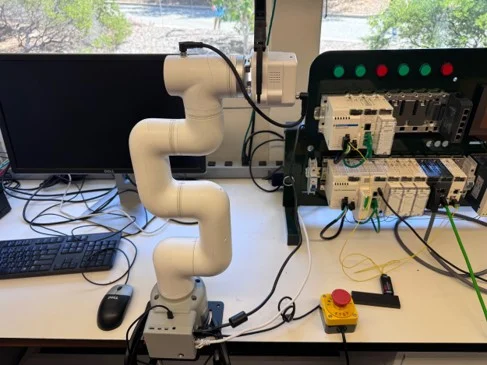
Thesis project coordinating a robot and conveyor subsystem through a safety-interlocked state machine, integrating a Schneider M580 PLC with a real-time RS-485/HMI interface for guided test…
IEC 61131-3 Structured TextPLC programming (Schneider M580)EtherNet/IPRS-485Python (multithreading)HMI design
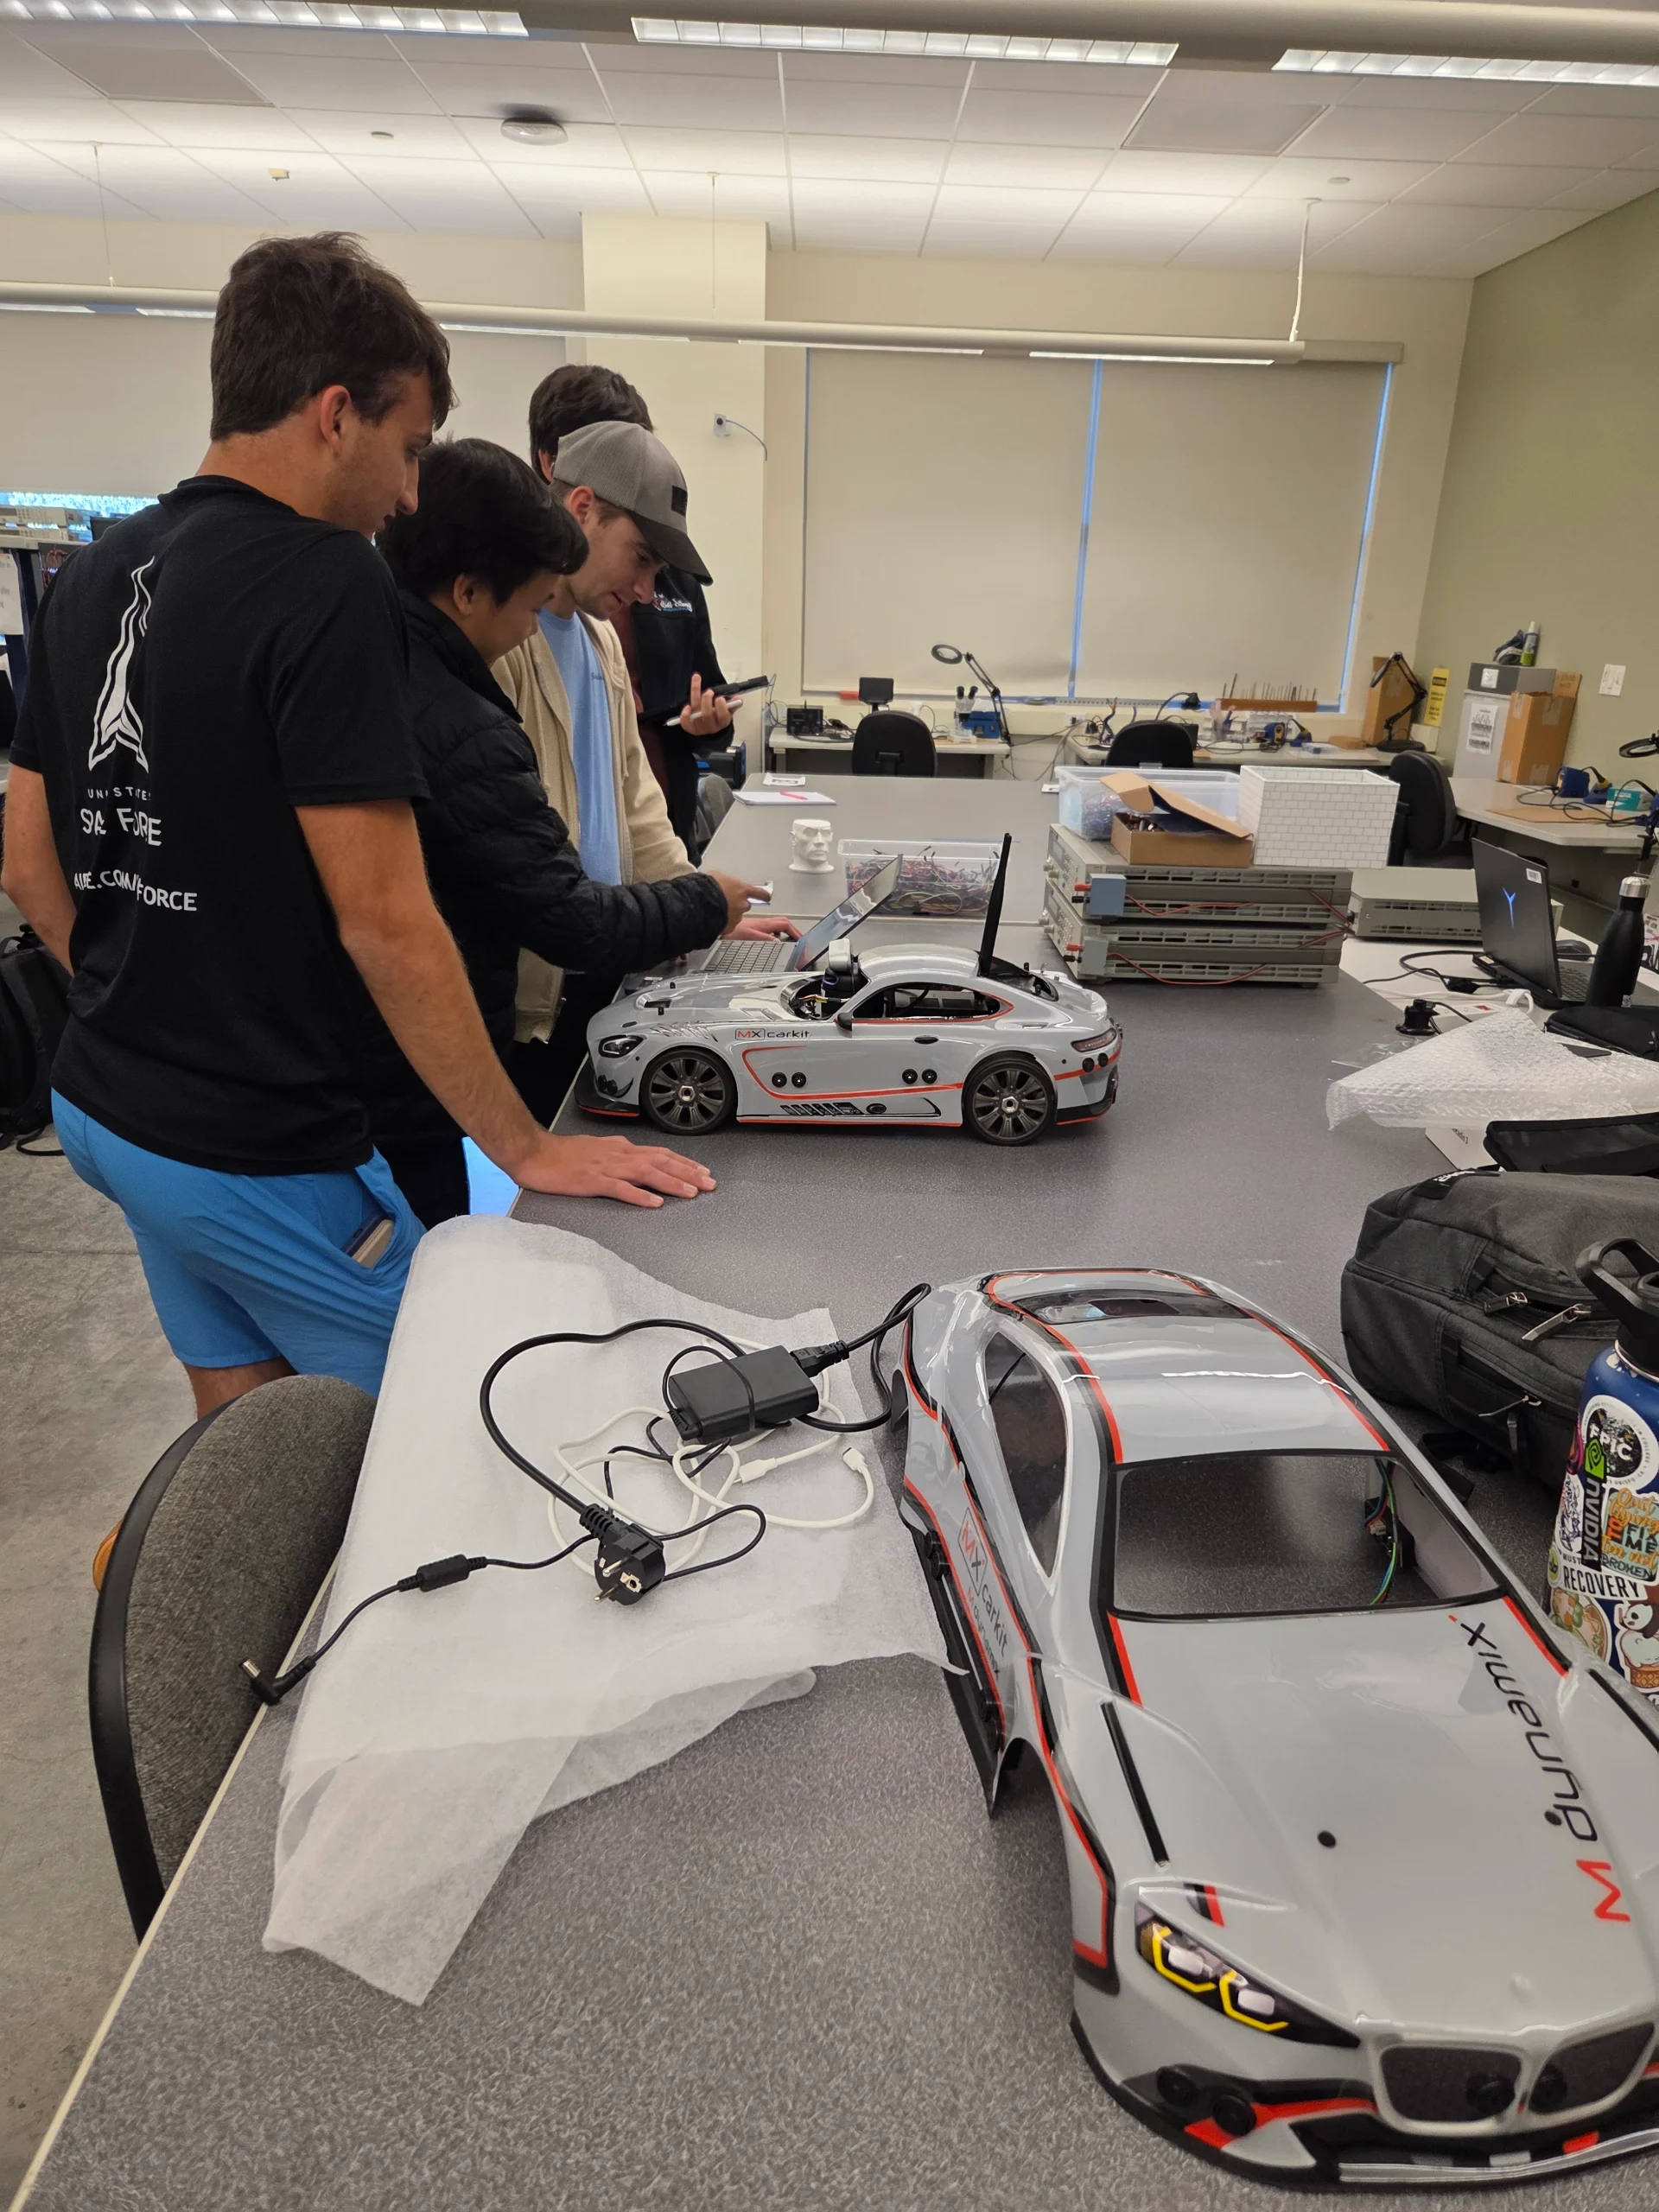
Autonomous Vehicle Perception and Control System

Autonomous Vehicle Perception and Control System

An autonomous driving workflow on an NVIDIA Jetson combining ROS 2, real-time sensor visualization, and a YOLO-based perception model to detect and respond to traffic signs.
ROS 2DockerNVIDIA JetsonFoxglovePythonYOLO (segmentation)computer vision
Battleship on the STM32 Microcontroller

Battleship on the STM32 Microcontroller

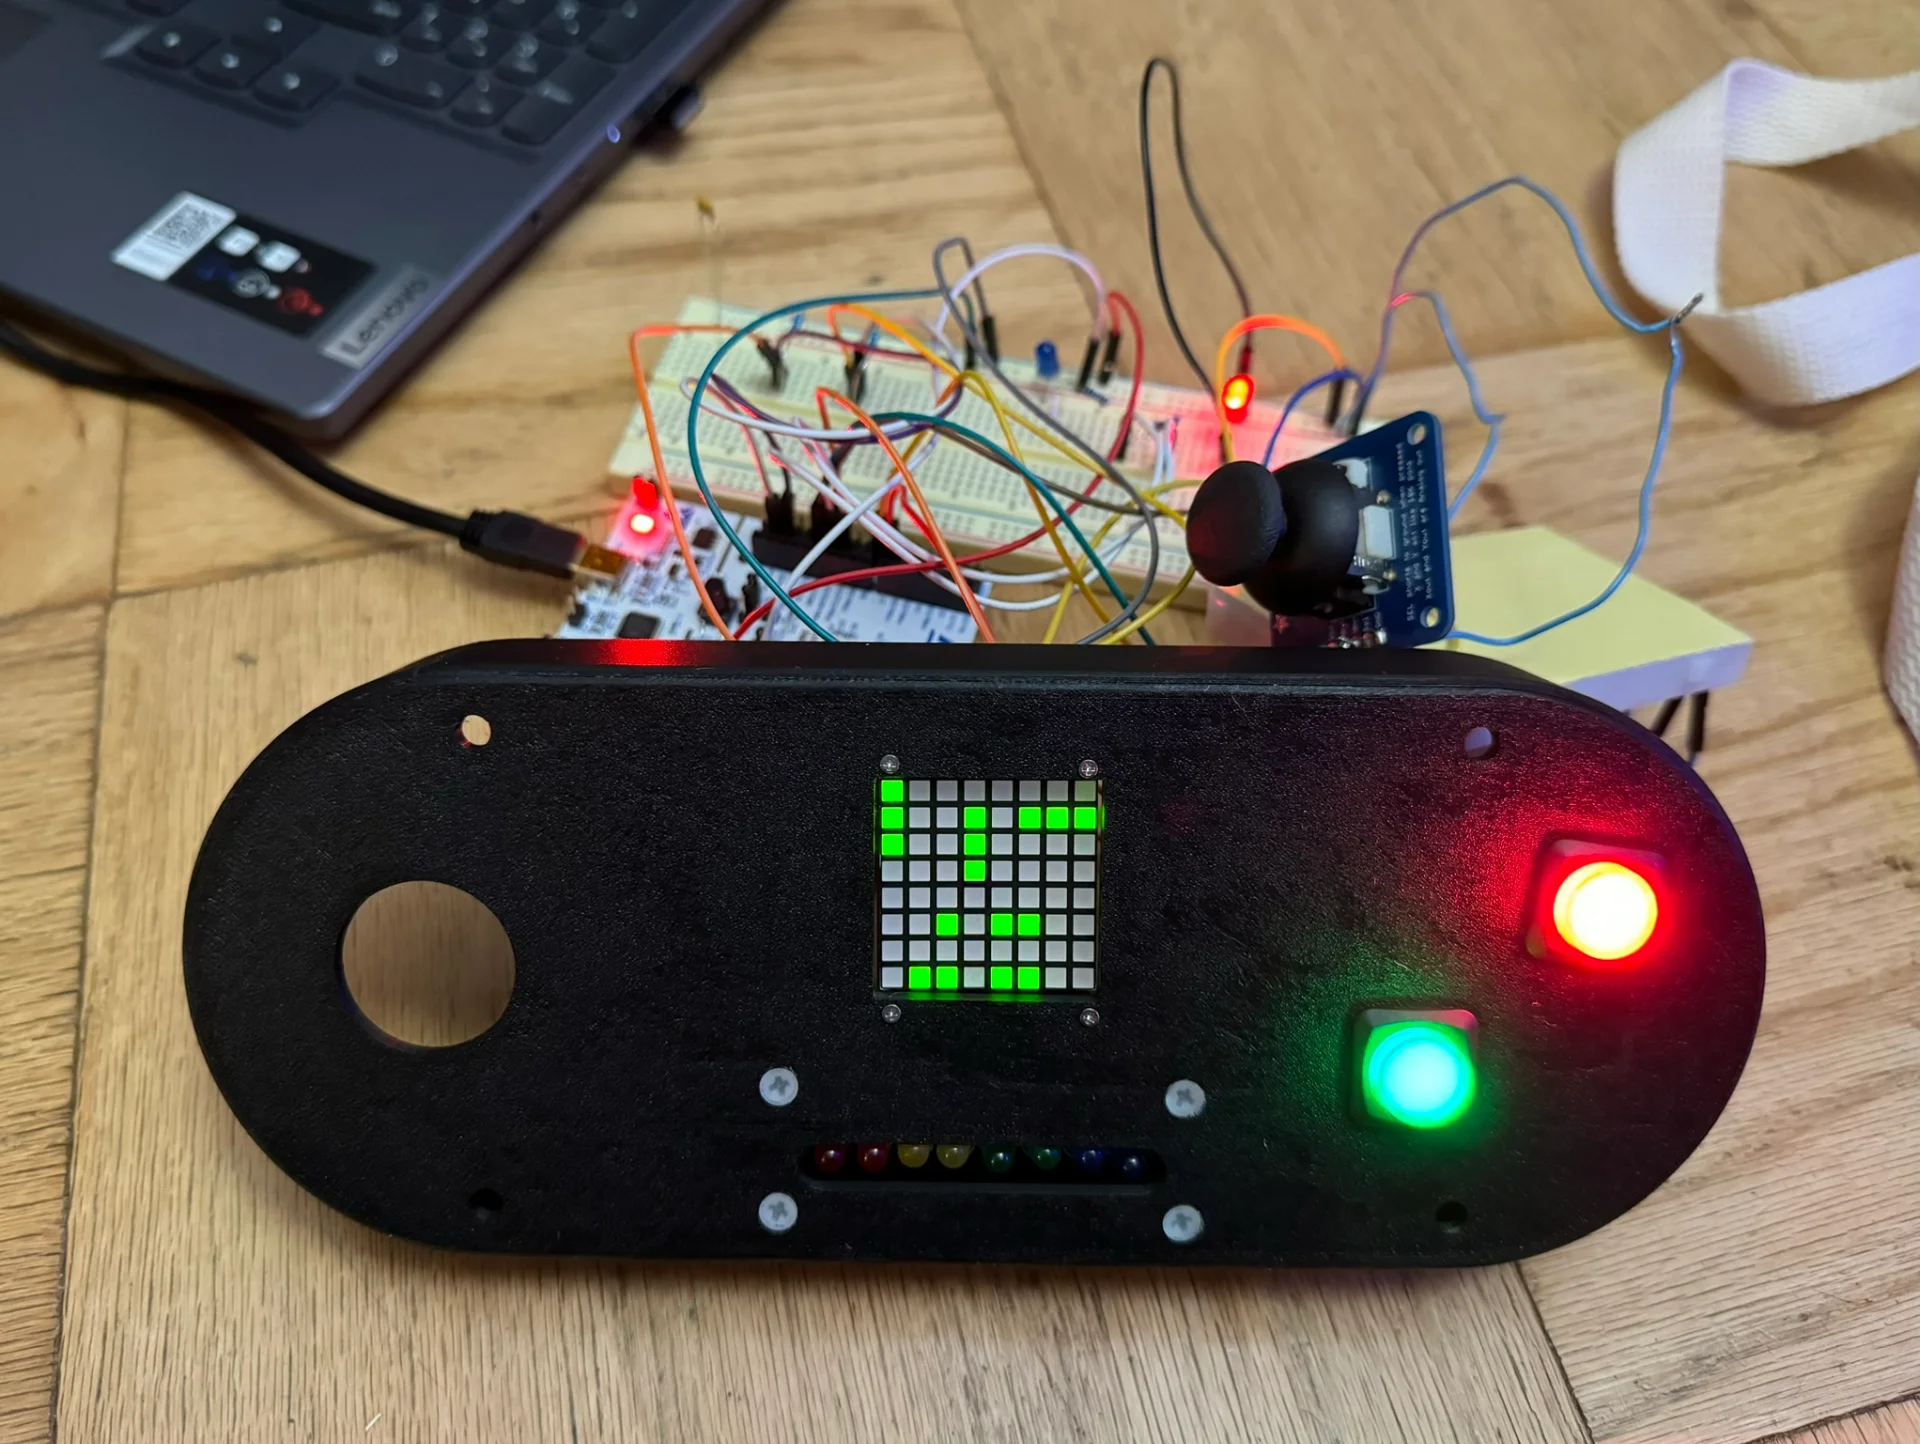
A simplified, two-player version of Battleship built on an STM32 microcontroller with a custom PCB and enclosure. Joystick and button inputs drive an 8x8 bicolor LED grid that tracks cursor position, hits, and…
C (bare-metal)STM32F4ADC (12-bit, interrupt-driven)I2CGPIOtimersPCBA bring-up/debugFusion360State Machines
Scalable Multi-Peripheral I2C Controller

Scalable Multi-Peripheral I2C Controller

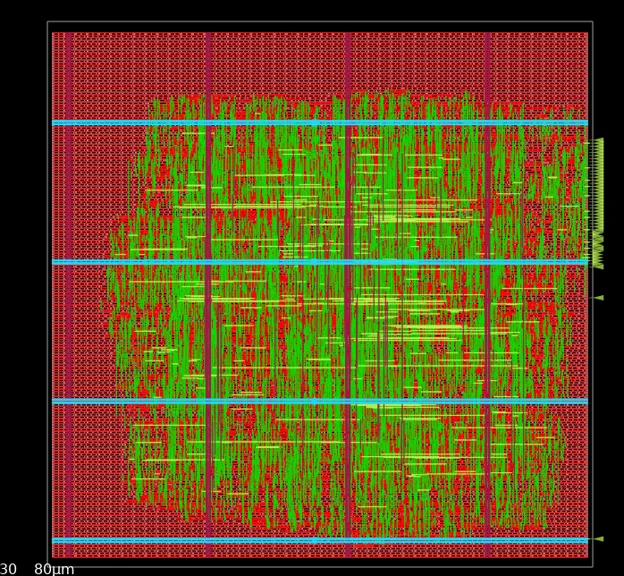
A SystemVerilog I2C controller taken through a full RTL-to-GDSII ASIC flow using OpenLane and Vivado, including verification, timing, and physical design closure.
SystemVerilogFPGARTL designOpenLaneVivadoASIC flow (RTL-to-GDSII)testbench developmenttiming verification (setup/hold, slack analysis)clock constraint optimization
Automated CI/CD Pipeline for HIL Testing

Automated CI/CD Pipeline for HIL Testing

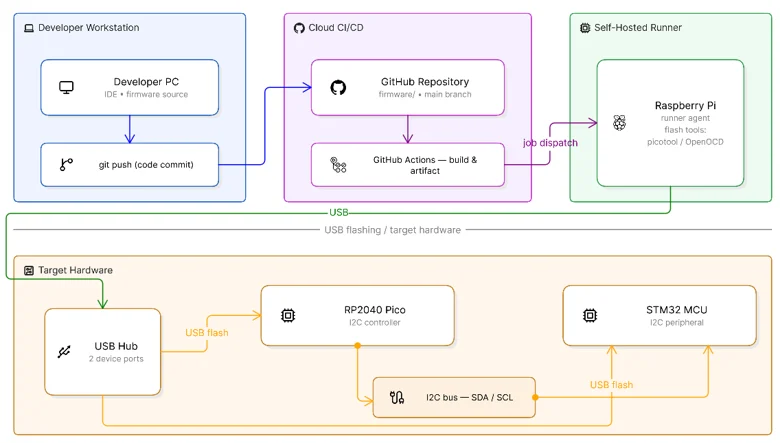
A GitHub Actions–based CI/CD pipeline that automates firmware flashing and CMake builds for hardware-in-the-loop (HIL) testing, with configurable fault injection.
CI/CDHardware-in-The-Loop (HIL) TestingGitHub ActionsCMakeBashJSON ConfigurationAutomation