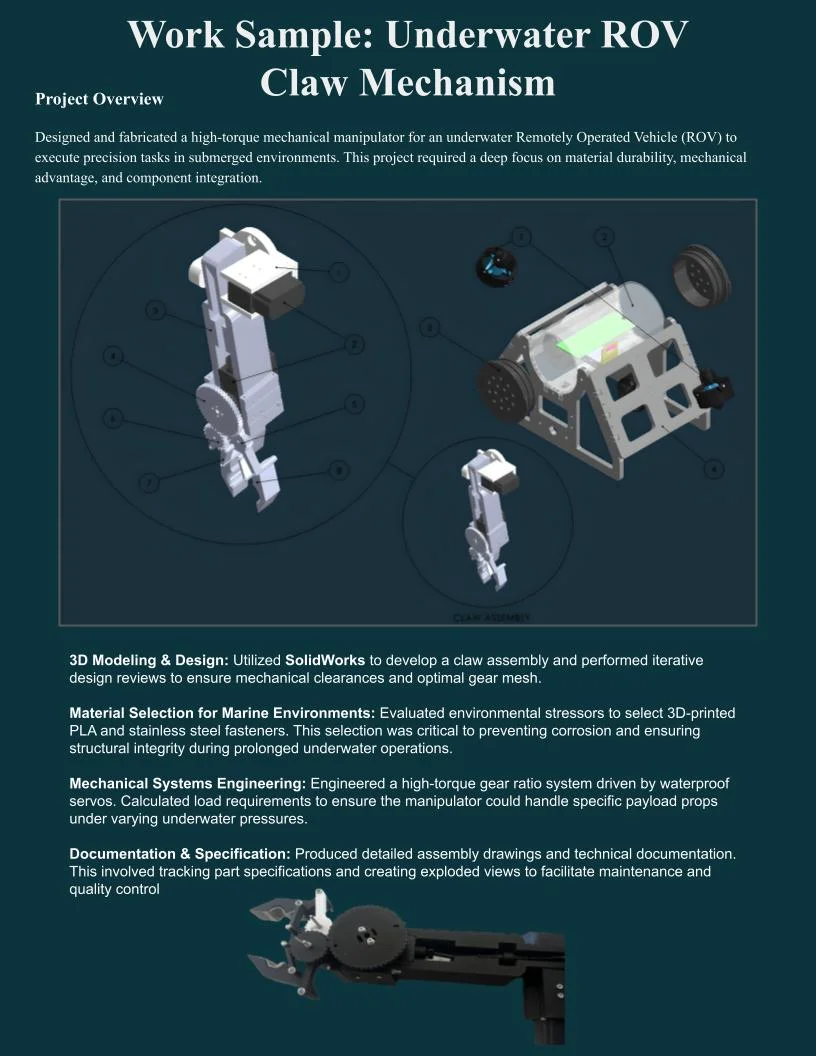
Underwater Robot Modular Claw System
The purpose of designing this claw system was to enable our Remotely Operated Vehicle (ROV) to perform various tasks for the MATE ROV competition that involved grabbing various objects which required different methods. I designed the claw to have 2 degrees of freedom for movement, as well as…
Solidworks3-D Printing